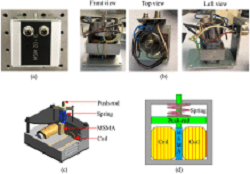
Sophia University, Japan, researchers have developed a new control scheme for the magnetic shape memory alloy-based actuator (MSMA-BA) that improves its positioning accuracy.
While MSMA-BA is a crucial component for high-precision positioning systems due to its high precision, low energy consumption, and large stroke, its hysteresis is an intrinsic property that can negatively affect its positioning accuracy. The team proposed a multi meta-model approach that combines the nonlinear auto-regressive moving average with exogenous inputs (NARMAX) and Bouc–Wen (BW) models to describe the dynamic hysteresis of MSMA-BA.
A wavelet neural network (WNN) was used to construct the nonlinear function of the multi meta-model, while iterative learning control was combined with a WNN to improve convergence speed. The proposed iterative learning controller was tested on MSMA-BA, with experiments demonstrating the scheme’s validity. The study’s main contribution was the convergence analysis of the iteration learning controller with iteration-dependent uncertainties.